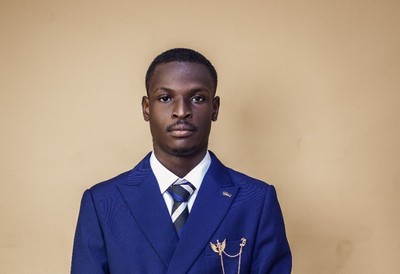
Robotics & AI Engineer

Mahmud Lawal.

I build end-to-end autonomous systems, from control algorithms and computer-vision pipelines to edge-deployed models that run in the real world. Mechatronics by training, AI by obsession.

📍 Abuja, Nigeria 🎓 B.Eng Mechatronics, ABU Zaria
Mahmud Lawal
About

I'm a Mechatronics engineer who designs and ships end-to-end AI systems. My work sits where perception meets control: real-time object detection and tracking, image and video analytics, and deep-learning models optimized to run on constrained edge hardware.

I led the Robotics & Automation Division at RAIN-INN ABU, mentoring on ROS, computer vision, and model deployment. Along the way I've competed on global stages, from the Shell Autonomous Programming Competition (first team from Sub-Saharan Africa to compete) to winning Wema Hackaholics 6.0.

I'm currently a remote ML Researcher with the CMU ML Research Collective, a student-led research group at Carnegie Mellon University, focusing on efficient ML for embodied AI: getting perception and navigation models to run well on CPU-only and edge hardware.

This site is also where I explore writing.

Toolkit

Skills & technologies

The stack I reach for across perception, learning, and deployment.

01 Languages

PythonC++SQL

02 Machine Learning & AI

PyTorchTensorFlowKerasScikit-learnLightGBMLangChainLangGraphLlama 3 / Vision

03 Computer Vision

YOLO v5/v8OpenCVObject TrackingSegmentationVideo Analytics

04 Backend & Deployment

FastAPIREST APIsDockerEdge / Raspberry PiAsync Processing

05 Robotics & Hardware

ROSEmbedded SystemsSensor IntegrationPLC / AutomationControl

06 Tools

GitLinuxVS CodeJupyterNumPy / PandasMatplotlib
Credentials

Certifications & specializations

Verified coursework across AI engineering, robotics, and software.

ROS 2 Specialization

Packt · 2 courses completed

In progress, latest September 2026

Self-Driving Cars Specialization

University of Toronto

Completed August 2026

AI Agents and Agentic AI Systems Development

Meta AI Developer Academy · RAIN

Completed December 2025

Shell Eco-marathon Autonomous Programming Competition 2025

Shell Eco-marathon · Team ABU Zaria

Participated May 2025

IBM AI Engineering Professional Certificate

IBM

Completed May 2024

Python for Everybody Specialization

University of Michigan

Completed September 2022

Selected work

Projects & competitions

End-to-end systems across vision, language, and autonomy, several battle-tested in hackathons and global competitions.

Semantic Object-Finding Robot

A TurtleBot 4 that explores an unknown house on its own, learns where the objects are with a CPU-only YOLO detector, and drives to them by name: say "go to the fridge" and it goes. Detections are lifted into 3D with the depth camera and fused into a persistent semantic map, and every result is scored against the simulator's ground truth.

89%of the house mapped on its own, no teleop
72%of "go to" commands reached the right object
0 / 60navigation failures across three full runs
ROS 2Nav2SLAMYOLO11nOpenVINOGazeboDocker

AutoPark: Vision-Based Autonomous Parking

A simulated car drives down a parking aisle, finds a free space using only its four fisheye cameras and wheel odometry, then reverses into it on its own. Every part of the stack is built from scratch in ROS 2 and Webots: a bird's-eye view from the cameras, a CNN slot detector, a Kalman filter per slot, a Hybrid A* planner with Reeds-Shepp curves and a Stanley controller.

12 / 12test scenarios parked with no contact
1 to 2 cmmedian distance from the slot centre
99.7%of slots detected, even with the car turned past 45°
ROS 2WebotsPyTorchOpenCVKalman FilterHybrid A*

ASL Fingerspelling: Tutor + Video Translator

In progress

Recognises American Sign Language fingerspelling from a webcam or any video, on a laptop CPU with no GPU. A live tutor watches you sign and says exactly what to fix; a translator turns fingerspelling video into subtitles, now with a small sequence model trained on 87 real-world signers. Tested openly on people it has never seen, with every result published, good or bad.

67%letter accuracy on 36 real-world signers it never saw (ChicagoFSWild)
25% → 67%per-frame system vs. sequence model on those signers
1 → 12 / 26letters on a stranger's video after one root-cause fix (the video)
MediaPipeOpenCVNumPyPyTorch (training)CTCPython

Test video: Travis Dougherty, ASL demo, by Fuzheado, CC BY-SA 3.0, via Wikimedia Commons. Demo video CC BY-SA 3.0.

AI-Based Smart Surveillance

Final Year Project

Event-driven surveillance with a PIR + Raspberry Pi camera wake-trigger, YOLO object detection via the OpenCV DNN module, low-latency edge inference, and real-time email threat alerts.

YOLOOpenCV DNNRaspberry PiEdge AI

Wema Hackaholics 6.0

🏆 Winner

Solved the “borderless office” problem with a dual-chatbot system for secure employee access: a WhatsApp-integrated assistant plus an identity-verification chatbot. Awarded overall winners.

AI ChatbotsWhatsAppAuth

Meta AI “SharpShop” Visual Commerce

Visual-first product discovery engine using vision-language models (Llama Vision) to extract features from product images, with OpenCV normalization and a LangGraph + FastAPI backend.

Llama VisionLangGraphFastAPIOpenCV

Graduate Career Agent

Meta AI Academy

AI career coach built on FastAPI + Meta Llama 3: context-aware chat, a CV-tailoring engine that parses PDFs for gap analysis, ATS score estimation, and skill categorization, all containerized with Docker.

Llama 3FastAPIDockerHugging Face

Shell Autonomous Programming

Spearheaded the control algorithm for autonomous navigation and obstacle avoidance. First team from Sub-Saharan Africa to compete, and secured a global leaderboard placement.

ROSRoboticsControl

Zindi Traffic Congestion Analytics

End-to-end video analytics pipeline classifying urban traffic congestion: YOLOv8 for real-time tracking, LightGBM for classification, with temporal lag/delta features for traffic-momentum accuracy.

YOLOv8OpenCVLightGBMTime-Series

Zindi Crop Disease Detection

YOLO-based computer-vision system for crop-disease identification: multi-stage segmentation and classification with a robust preprocessing pipeline, optimized for offline edge detection on the farm.

YOLOOpenCVEdge Deployment
Writing

From the blog

This is where I explore writing.

Browse the writing
Get in touch

Let's build something autonomous.

Open to roles and collaborations in robotics, computer vision, and applied AI.